TopPodcast.com
Menu
  • Home
  • Top Charts
  • Top Networks
  • Top Apps
  • Top Independents
  • Top Podfluencers
  • Top Picks
    • Top Business Podcasts
    • Top True Crime Podcasts
    • Top Finance Podcasts
    • Top Comedy Podcasts
    • Top Music Podcasts
    • Top Womens Podcasts
    • Top Kids Podcasts
    • Top Sports Podcasts
    • Top News Podcasts
    • Top Tech Podcasts
    • Top Crypto Podcasts
    • Top Entrepreneurial Podcasts
    • Top Fantasy Sports Podcasts
    • Top Political Podcasts
    • Top Science Podcasts
    • Top Self Help Podcasts
    • Top Sports Betting Podcasts
    • Top Stocks Podcasts
  • Podcast News
  • About Us
  • Podcast Advertising
  • Contact
Not in our directory?
Add Show Here
Podcast Equipment
Center

toppodcastlogoOur TOPPODCAST Picks

  • Comedy
  • Crypto
  • Sports
  • News
  • Politics
  • True Crime
  • Business
  • Finance

Follow Us

toppodcastlogoStay Connected

    View Top 200 Chart
    Back to Rankings Page
    Technology

    Robohub Podcast

    News and views on current and future trends in robot technology and artificial intelligence.

    Advertise

    Copyright: © Robohub Podcast

    • Apple Podcasts
    • Google Play
    • Spotify

    Latest Episodes:
    ep.256: Socially Assistive Robots, with Maja Matarić Mar 19, 2018
    Show notes
    In this episode, Audrow Nash speaks with Maja Matarić, a professor at the University of Southern California and the Chief Science Officer of Embodied, about socially assistive robotics. Socially assistive robotics aims to endow robots with the ability to help people through individual non-contact assistance in convalescence, rehabilitation, training, and education. For example, a robot could help a child on the autism spectrum to connect to more neurotypical children and could help to motivate a stroke victim to follow their exercise routine for rehabilitation (see the videos below). In this interview, Matarić discusses the care gap in health care, how her work leverages research in psychology to make robots engaging, and opportunities in socially assistive robotics for entrepreneurship.

    ep.255: Learning about Legged Locomotion from Birds, with Monica Daley Mar 04, 2018
    Show notes
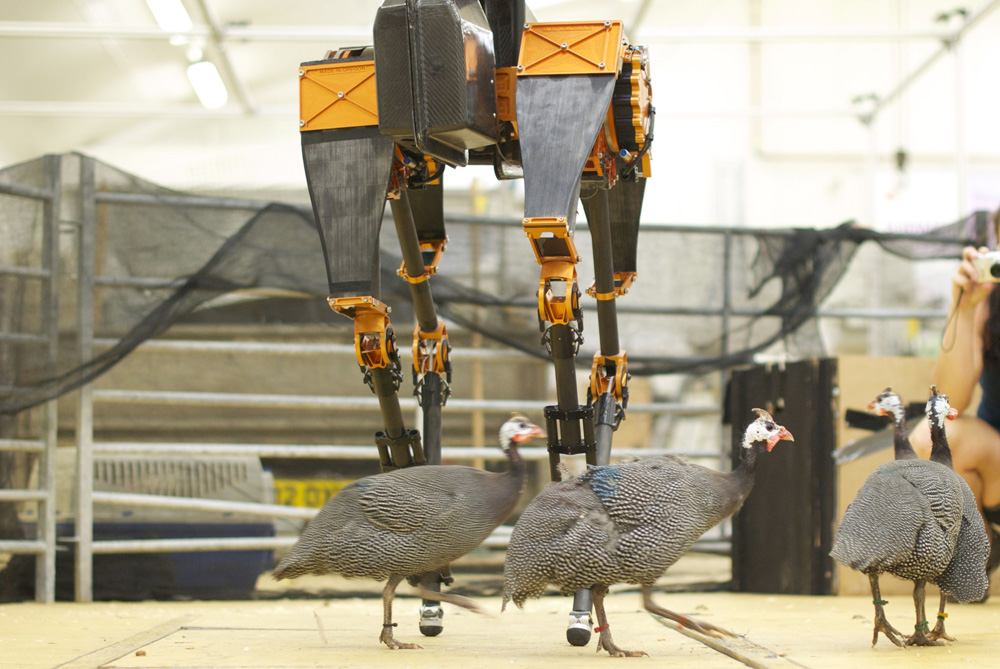
    In this episode, Audrow Nash speaks with Monica Daley about learning from birds about legged locomotion. To do this, Daley analyzes the gaits of guineafowl in various experiments to understand the mechanical principles underlying gaits, such as energetic economy, mechanical limits, and how the birds avoid injury. She then tests her ideas about legged locomotion on legged robots with collaborators, including Jonathan Hurst from Oregon State University. Daley also speaks about her experience with interdisciplinary collaborations.

    ep.254: Collaborative Systems for Drug Discovery, with Peter Harris Feb 18, 2018
    Show notes
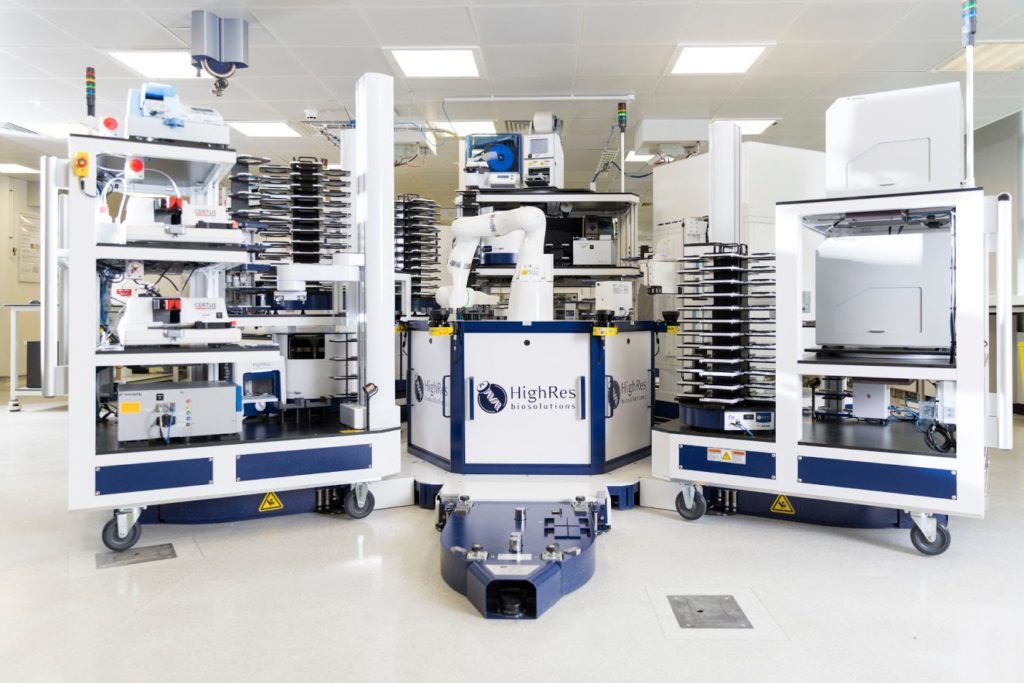
    In this episode, Abate interviews Peter Harris from HighRes Biosolutions about automation in the field of drug discovery. At HighRes Biosolutions they are developing modular robotic systems that work alongside scientists to automate laboratory tasks. Because the requirements of each biomedical research laboratory are so varied, the robotic systems are specifically tailored to meet the requirements of each lab.

    ep.253: eSIM in Wearable Technology, with Karl Weaver Feb 05, 2018
    Show notes
    In this episode, Audrow Nash speaks with Karl Weaver (魏卡爾), formerly the Original Equipment Manufacturer Business Development Director for Oasis Smart SIM. Weaver discusses how wearable technology is growing as a form of payment system in China. He speaks about wireless technology, including Near-Field Communications (NFC) and Embedded SIM cards (eSIM), in wearable technology and in other applications, such as bike rental.

    ep.252: Embedded Platform for SLAM, with Zhe Zhang Jan 20, 2018
    Show notes
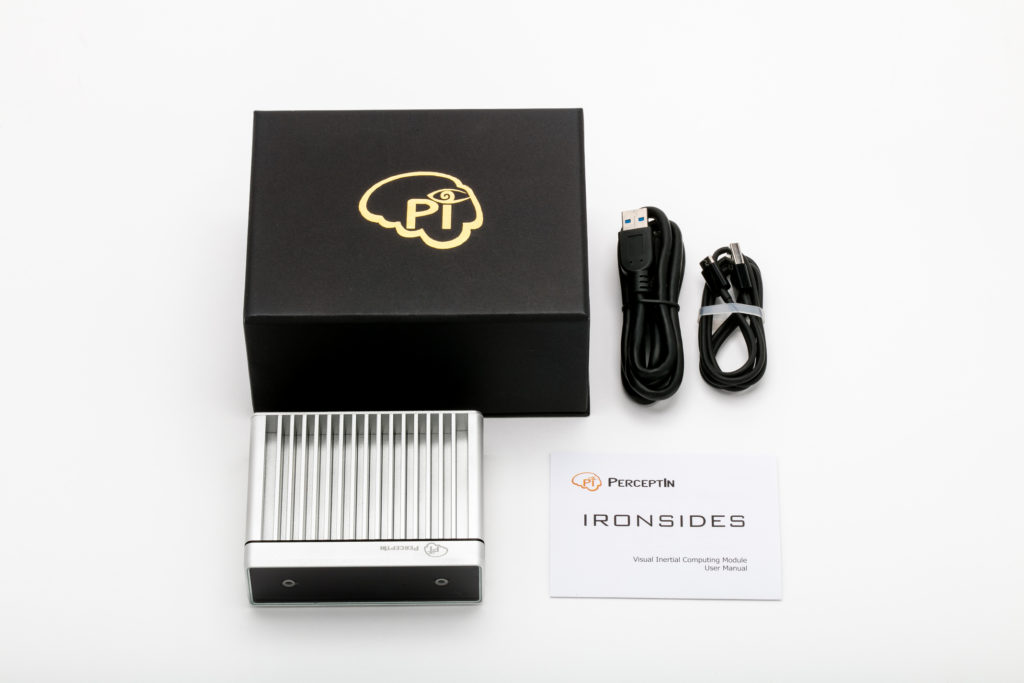
    In this episode Abate talks with Zhe Zhang from Perceptin where they are building embedded platforms for robots to do Simultaneous Localization and Mapping (SLAM) algorithms in real time. Zhe explains the methods they incorporate such as sensor fusion and hardware synchronization to make a highly accurate SLAM platform for IOT, consumer, and automotive grade robots.

    ep.251: Open Source Prosthetic Leg, with Elliott Rouse Jan 06, 2018
    Show notes
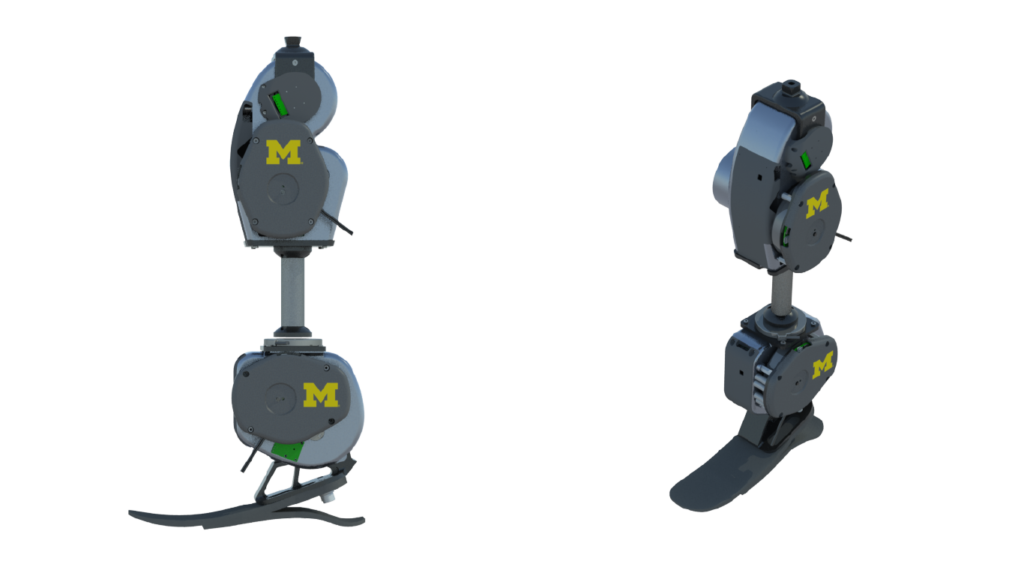
    In this episode, Audrow Nash interviews Elliott Rouse, Assistant Professor at the University of Michigan, about an open-source prosthetic leg—that is a robotic knee and ankle. Rouse’s goal is to provide an inexpensive and capable platform for researchers to use so that they can work on prostheses without developing their own hardware, which is both time-consuming and expensive. Rouse discusses the design of the leg, the software interface, and the project's timeline.

    ep.250: Learning Prosthesis Control Parameters, with Helen Huang Dec 24, 2017
    Show notes
    In this interview, Audrow Nash interviews Helen Huang, Joint Professor at the University of North Carolina at Chapel Hill and North Carolina State, about a method of tuning powered lower limb prostheses. Huang explains how powered prostheses are adjusted for each patient and how she is using supervised and reinforcement learning to tune prosthesis. Huang also discusses why she is not using the energetic cost of transport as a metric and the challenge of people adapting to a device while it learns from them.

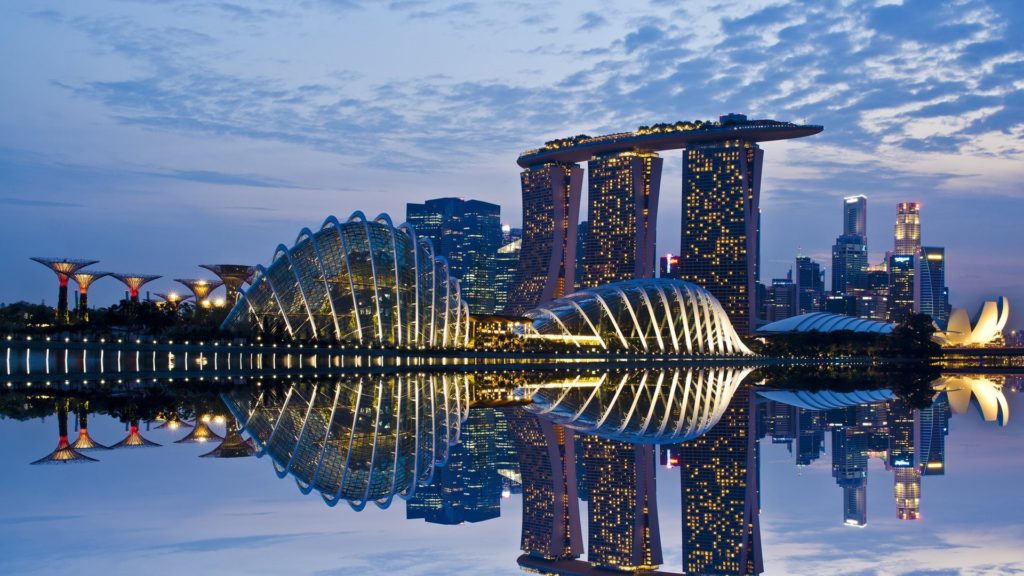
    ep.249: ICRA 2017 Company Showcase, with Howard Michel, Li Bingbing, Xianbao Chen and Lester Teh Chee Onn Dec 10, 2017
    Show notes
    In this episode, Audrow Nash interviews several companies at the International Conference for Robotics and Automation (ICRA). ICRA is the IEEE Robotics and Automation Society’s biggest conference and one of the leading international forums for robotics researchers to present their work.

    ep.248: Semi-active Prostheses, with Peter Adamczyk Nov 24, 2017
    Show notes
    In this episode, Audrow Nash interviews Peter Adamczyk, Assistant Professor at the University of Wisconsin-Madison, on semi-active foot and ankle prostheses. The difference is that active below-knee prostheses work to move the person’s weight, emulating the calf muscle, while semi-active devices use small amounts of power to improve the performance of the prosthesis. Adamczyk discusses the motivation for semi-active devices and gives three examples: shiftable shapes, controllable keels, and alignable ankles.

    ep.247: ANYmal: A Ruggedized Quadrupedal Robot, with Marco Hutter Nov 11, 2017
    Show notes
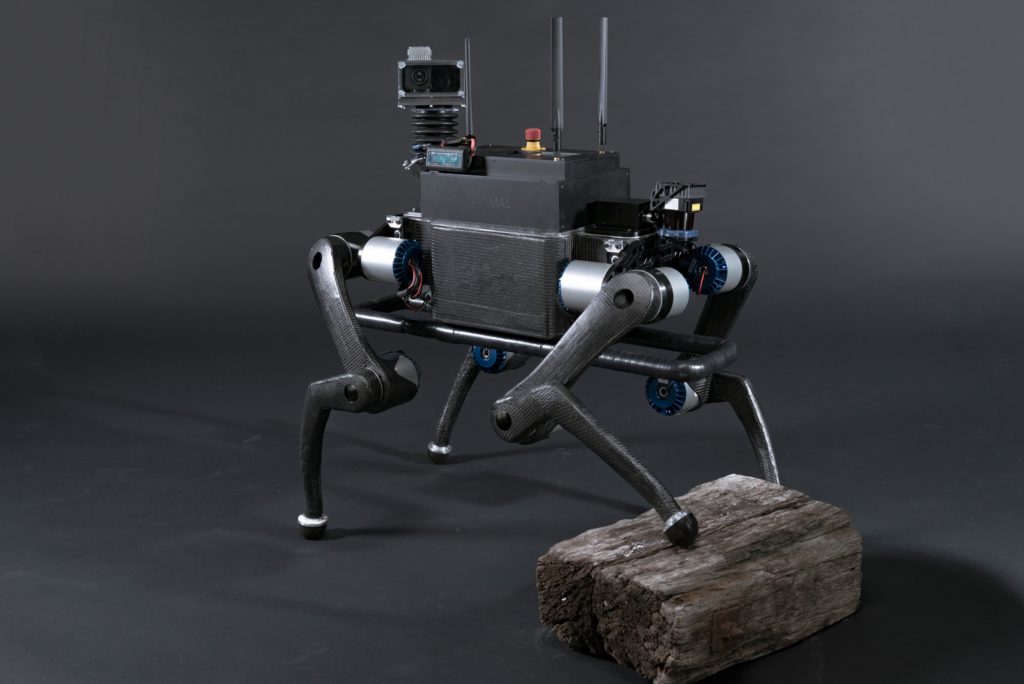
    In this interview, Audrow Nash interviews Marco Hutter, Assistant Professor for Robotic Systems at ETH Zürich, about a quadrupedal robot designed for autonomous operation in challenging environments, called ANYmal. Hutter discusses ANYmal's design, the ARGOS oil and gas rig inspection challenge, and the advantages and complexities of quadrupedal locomotion.

    Previous 1 10 11 12 13 14 32 Next

    Related Podcasts

    Reply All

    1

    Reply All Games & Hobbies
    Inside VR & AR

    2

    Inside VR & AR Gadgets
    Note to Self

    3

    Note to Self News
    BrainStuff

    4

    BrainStuff Natural Sciences
    This Week in Tech (Audio)

    5

    This Week in Tech (Audio) News
    Hands-On Tech (Audio)

    6

    Hands-On Tech (Audio) Technology
    footer-logo

    Contact Us

    Toll Free: 844-670-7747

    Links

    • Home
    • Top Charts
    • Networks
    • Apps
    • Independents Podcasts
    • Podcast Advertising
    • Podcast News
    • Contact Us
    • About Us
    • Analytics & Insights

    Stay Connected

      Privacy, Terms of Use & Our Code of Ethics Protecting Content Creators Copyrights